|
Valkyrie 2026
|
|
Valkyrie 2026
|
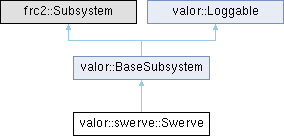
Public Member Functions | |
| Swerve (std::string name, std::vector< SwerveModule::Config > moduleConfigs, std::shared_ptr< gyro::Gyro > gyro, units::meter_t wheelDiameter, frc2::sysid::Config=frc2::sysid::Config{std::nullopt, std::nullopt, std::nullopt, nullptr}) | |
| void | AnalyzeDashboard () override |
| Synchronize dashboard data (both read and write). | |
| void | LoggablePeriodic () override |
| Periodic callback for logging updates. | |
| void | Reset () override |
| Reset all subsystem state. | |
| void | StartOdomThread (units::hertz_t freq) |
| void | SimulationPeriodic () override |
| void | ResetGyro () |
| void | ApplyRequest (requests::TrackAngularPosition) |
| void | ApplyRequest (requests::ApplyChassisSpeeds) |
| void | ApplyRequest (requests::ApplyStates) |
| frc2::CommandPtr | SysIdQuasistatic (frc2::sysid::Direction d) |
| frc2::CommandPtr | SysIdDynamic (frc2::sysid::Direction d) |
| void | ResetOdometry (FrameWrapper< FieldFrame, frc::Pose2d > pose) |
| void | ResetEncoders () |
| double | GetSkiddingRatio () |
| bool | IsRobotSkidding () |
| constexpr std::vector< std::unique_ptr< SwerveModule > > & | GetModules () |
| void | UpdateAngularAcceleration () |
| Updates the calculated angular acceleration of the robot. This function uses the current and previous yaw rates from the gyroscope to compute the angular acceleration. | |
| units::angular_acceleration::radians_per_second_squared_t | GetSmoothedAngularAcceleration () |
| double | RotationLerping (double) |
| constexpr const auto & | GetState () const |
| constexpr auto & | GetState () |
| Public Member Functions inherited from valor::BaseSubsystem | |
| BaseSubsystem (std::string name) | |
| Construct a new Valor Subsystem object. | |
| virtual void | AssessInputs () |
| Read controller logic and set subsystem state. | |
| virtual void | AssignOutputs () |
| Read subsystem state and send motor commands. | |
| void | SetGamepads (valor::Gamepad *_operatorGamepad, valor::Gamepad *_driverGamepad) |
| Public Member Functions inherited from valor::Loggable | |
| Loggable (std::string_view name) | |
| Construct a Loggable that registers a top-level table name. | |
| Loggable (std::shared_ptr< nt::NetworkTable > table) | |
| Construct a Loggable that uses an existing NetworkTable. | |
| Loggable ()=default | |
| Default construct an uninitialized Loggable. | |
| void | LogChild (std::string_view name, Loggable *child) |
| Register a child Loggable under a named subtree. | |
| void | LogChild (std::string_view name, wpi::Sendable *child) |
| Register a child Sendable under a named subtree. | |
| bool | WriteLog (std::string_view field, bool data) |
| double | WriteLog (std::string_view field, double data) |
| void | WriteLog (std::string_view field, const std::vector< double > &data) |
|
template<typename U> requires units::traits::is_unit_t_v<U> | |
| U | WriteLog (std::string_view field, U data) |
| void | WriteLog (std::string_view field, std::string_view data) |
|
template<typename E> requires std::is_enum_v<E> | |
| void | WriteLog (std::string_view field, E data) |
|
template<typename T> requires wpi::StructSerializable<T> && (!std::is_arithmetic_v<T>) | |
| void | WriteLog (std::string_view field, const T &data) |
|
template<typename T> requires wpi::StructSerializable<T> && (!std::is_arithmetic_v<T>) | |
| void | WriteLog (std::string_view field, const std::vector< T > &data) |
| bool | ReadLog (std::string_view field, bool defaultValue) |
| double | ReadLog (std::string_view field, double defaultValue) |
|
template<typename U> requires units::traits::is_unit_t_v<U> | |
| U | ReadLog (std::string_view field, U defaultValue) |
Protected Member Functions | |
| void | EnableCarpetGrain (double grainMultiplier, bool roughTowardsRed) |
| FrameWrapper< FieldFrame, frc::ChassisSpeeds > | VectorLockedSpeeds (FrameWrapper< FieldFrame, frc::ChassisSpeeds > speeds, FrameWrapper< FieldFrame, frc::Rotation2d > heading) |
| void | UpdateOdometry () |
| void | SetRotationalLerpMap (wpi::interpolating_map< double, double > _interpolationMap) |
| ConvexPolygon | GetPolygon () const |
| Protected Member Functions inherited from valor::Loggable | |
| virtual void | OnLoggingStart () |
| Hook invoked when logging is started for this object. | |
Static Protected Member Functions | |
| static FrameWrapper< FieldFrame, frc::ChassisSpeeds > | ReflectDriveSpeeds (FrameWrapper< FieldFrame, frc::ChassisSpeeds > unreflectedSpeeds) |
Protected Attributes | |
| FrameWrapper< FieldFrame, frc::ChassisSpeeds > | commandedSpeeds |
| units::meters_per_second_t | maxDriveSpeed |
| units::radians_per_second_t | maxRotationSpeed |
| std::shared_ptr< gyro::Gyro > | gyro |
| ctre::phoenix6::swerve::impl::SwerveDriveKinematics | kinematics |
| util::Locked< ctre::phoenix6::swerve::impl::SwerveDrivePoseEstimator > | rawEstimator |
| util::Locked< ctre::phoenix6::swerve::impl::SwerveDrivePoseEstimator > | calcEstimator |
| std::vector< std::unique_ptr< SwerveModule > > | swerveModules |
| frc::Timer | resetOdom |
| valor::ProfiledPIDController< units::radian, units::radians_per_second > | rotationController {{}} |
| Used for requests::TrackAngularPosition. | |
| Protected Attributes inherited from valor::BaseSubsystem | |
| valor::Gamepad * | operatorGamepad = nullptr |
| valor::Gamepad * | driverGamepad = nullptr |
Additional Inherited Members | |
| Static Public Member Functions inherited from valor::Loggable | |
| static constexpr Loggable & | GetRoot () |
|
overridevirtual |
Synchronize dashboard data (both read and write).
The analyzeDashboard function runs at all times (disabled, auto, and teleop). The intent of the function is to send sensor and state information from the robot to the Driver Station for debugging. Additionally, driver commands and data can be sent from the Driver Station to the robot and collected in this function.
ALL network table and sensor logic should be in this function as both network table and sensor information should be read at all times, not just during teleop since auto will never get that information.
This function is a virtual function and should be implemented by the subsystem.
Reimplemented from valor::BaseSubsystem.
|
overridevirtual |
Periodic callback for logging updates.
If a derived class needs to perform periodic updates to published values, override this method. It is intended to be called by the logging framework; this base class provides an empty implementation.
Reimplemented from valor::Loggable.
|
overridevirtual |
Reset all subsystem state.
Use this function to set the subsystem state to default values, as well as set the motor outputs to 0 so the robot doesn't "lurch" when booting up due to phantom state (aka. state that was previously set but hasn't been reset yet).
This function is a virtual function and should be implemented by the subsystem.
Reimplemented from valor::BaseSubsystem.
| void valor::swerve::Swerve::ResetOdometry | ( | FrameWrapper< FieldFrame, frc::Pose2d > | pose | ) |
Reset the robot's position on the field. Any accumulted gyro drift will be noted and accounted for in subsequent calls to getPoseMeters()
| pose | The robot's actual position on the field |
|
protected |
|
protected |
 1.15.0