|
|
frc::Rotation2d | targetDirection |
| | Desired angular position in field space.
|
| frc::ChassisSpeeds | speeds |
| | Desired chassis-relative or field-relative motion.
|
| frc::Translation2d | centerOfRotation = {} |
| | Center of rotation for the drivetrain motion.
|
| std::vector< BaseController::Output > | feedforwards = {} |
| | Optional feedforward outputs for each swerve module.
|
| BaseController::Output | zeroOutput = 0 |
| | Default output value used when speeds are below the given deadband.
|
| OutputType | outputType = OutputType::Velocity |
| | Output control mode used when applying drive requests.
|
| bool | discretize = true |
| | Whether to discretize the chassis speeds.
|
| bool | desaturateWheelSpeeds = true |
| | Whether to desaturate wheel speeds.
|
| bool | optimizeModules = true |
| | Whether to optimize module states.
|
| bool | cosineScaling = true |
| bool | fieldRelative = true |
| | Whether the chassis speeds are field-relative.
|
| units::meters_per_second_t | deadband = 0_mps |
| | Minimum wheel speed required before motion is applied.
|
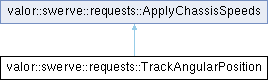
The documentation for this struct was generated from the following file:
- src/main/include/valkyrie/drivetrain/swerve/Requests.h
 1.15.0