|
Valkyrie 2026
|
|
Valkyrie 2026
|
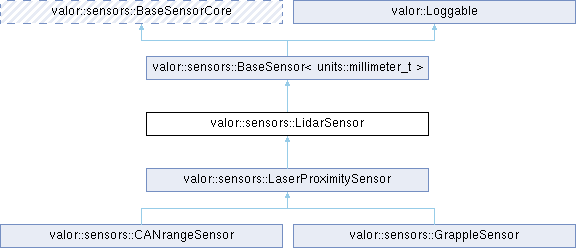
Specific implementation of the Lidar Sensor for Grapple Robotics LidarCAN device. More...
#include <valkyrie/sensors/LidarSensor.h>
Classes | |
| struct | SimState |
Public Member Functions | |
| LidarSensor () | |
| Construct a new LidarSensor object. | |
| void | SetMaxDistance (units::millimeter_t dist) |
| units::millimeter_t | GetMaxDistance () const |
| void | SetDefaultDistance (units::millimeter_t dist) |
| units::millimeter_t | GetDefaultDistance () const |
| virtual bool | IsHealthy () const |
| Represents whether the sensor data is healthy. | |
| void | SetupSim (std::function< frc::Pose2d()> robotPoseGetter, frc::Transform2d sensorPosition, std::vector< sim::FieldFeature > features) |
| void | SetGetter (std::function< units::millimeter_t()> getter) |
| void | LoggablePeriodic () override |
| Periodic callback for logging updates. | |
| Public Member Functions inherited from valor::sensors::BaseSensor< units::millimeter_t > | |
| virtual void | Reset () |
| Reset the sensor state. | |
| void | SetGetter (std::function< units::millimeter_t()> _lambda) |
| Set the lambda function to fetch sensor data. | |
| void | ApplyPostProcessing (std::function< units::millimeter_t(units::millimeter_t)> func) |
| Set a post-processing function for sensor data. | |
| units::millimeter_t | Get () const |
| Get the current sensor state. | |
| void | Refresh () override |
| Refresh the sensor state. | |
| Public Member Functions inherited from valor::sensors::BaseSensorCore | |
| virtual void | Calculate () |
| Public Member Functions inherited from valor::Loggable | |
| Loggable (std::string_view name) | |
| Construct a Loggable that registers a top-level table name. | |
| Loggable (std::shared_ptr< nt::NetworkTable > table) | |
| Construct a Loggable that uses an existing NetworkTable. | |
| Loggable ()=default | |
| Default construct an uninitialized Loggable. | |
| void | LogChild (std::string_view name, Loggable *child) |
| Register a child Loggable under a named subtree. | |
| void | LogChild (std::string_view name, wpi::Sendable *child) |
| Register a child Sendable under a named subtree. | |
| bool | WriteLog (std::string_view field, bool data) |
| double | WriteLog (std::string_view field, double data) |
| void | WriteLog (std::string_view field, const std::vector< double > &data) |
|
template<typename U> requires units::traits::is_unit_t_v<U> | |
| U | WriteLog (std::string_view field, U data) |
| void | WriteLog (std::string_view field, std::string_view data) |
|
template<typename E> requires std::is_enum_v<E> | |
| void | WriteLog (std::string_view field, E data) |
|
template<typename T> requires wpi::StructSerializable<T> && (!std::is_arithmetic_v<T>) | |
| void | WriteLog (std::string_view field, const T &data) |
|
template<typename T> requires wpi::StructSerializable<T> && (!std::is_arithmetic_v<T>) | |
| void | WriteLog (std::string_view field, const std::vector< T > &data) |
| bool | ReadLog (std::string_view field, bool defaultValue) |
| double | ReadLog (std::string_view field, double defaultValue) |
|
template<typename U> requires units::traits::is_unit_t_v<U> | |
| U | ReadLog (std::string_view field, U defaultValue) |
Protected Attributes | |
| std::unique_ptr< SimState > | simState |
| Protected Attributes inherited from valor::sensors::BaseSensor< units::millimeter_t > | |
| std::function< units::millimeter_t()> | sensorLambda |
| Lambda function to fetch sensor data. | |
| std::function< units::millimeter_t(units::millimeter_t)> | postProcessor |
| Lambda function to post-process sensor data. | |
| units::millimeter_t | prevState |
| Previous and current sensor states. | |
| units::millimeter_t | currState |
Additional Inherited Members | |
| Static Public Member Functions inherited from valor::Loggable | |
| static constexpr Loggable & | GetRoot () |
| Static Public Attributes inherited from valor::sensors::BaseSensorCore | |
| static constexpr units::millisecond_t | LOOP_PERIOD = frc::TimedRobot::kDefaultPeriod / 2 |
| Protected Member Functions inherited from valor::Loggable | |
| virtual void | OnLoggingStart () |
| Hook invoked when logging is started for this object. | |
Specific implementation of the Lidar Sensor for Grapple Robotics LidarCAN device.
This class extends the BaseSensor class and provides functionality specific to the Lidar sensor. It allows for fetching distance measurements and setting a maximum distance threshold.
| valor::sensors::LidarSensor::LidarSensor | ( | ) |
Construct a new LidarSensor object.
| robot | Reference to the robot, used to schedule the calculate method. |
|
inlinevirtual |
Represents whether the sensor data is healthy.
If the data is not healthy, LidarSensor will return the default distance instead of the sensor's getter
Reimplemented in valor::sensors::CANrangeSensor, and valor::sensors::GrappleSensor.
|
overridevirtual |
Periodic callback for logging updates.
If a derived class needs to perform periodic updates to published values, override this method. It is intended to be called by the logging framework; this base class provides an empty implementation.
Reimplemented from valor::Loggable.
 1.15.0