|
Valkyrie 2026
|
|
Valkyrie 2026
|
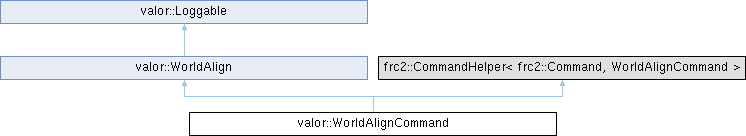
Public Member Functions | |
| WorldAlignCommand (swerve::Swerve &swerve) | |
| void | Initialize () override |
| void | Execute () override |
| bool | IsFinished () override |
| constexpr void | EnableRotation (bool e) |
| Public Member Functions inherited from valor::WorldAlign | |
| WorldAlign () | |
| Constructs a WorldAlign object. | |
| void | SetPID (TranslationalPIDF_t x, TranslationalPIDF_t y, RotationalPIDF_t rot) |
| A convenience method to set the PID gains for all three controllers at once. | |
| TranslationalPIDF_t | GetXPID () const |
| Gets the PID gains for the X-axis controller. | |
| TranslationalPIDF_t | GetYPID () const |
| Gets the PID gains for the Y-axis controller. | |
| RotationalPIDF_t | GetRotationalPID () const |
| Gets the PID gains for the rotation controller. | |
| void | ResetControllers (frc::Pose2d, frc::ChassisSpeeds) |
| Resets all controllers with the current robot state. This synchronizes the controller's internal state with the actual robot position and velocity. | |
| void | SetGoal (frc::Pose2d goal, frc::ChassisSpeeds state) |
| Sets the desired goal state for the alignment controllers. | |
| void | SetPositionTolerance (units::meter_t xTol, units::meter_t yTol, units::radian_t rotTol) |
| void | SetVelocityTolerance (units::meters_per_second_t xTol, units::meters_per_second_t yTol, units::radians_per_second_t rotTol) |
| std::pair< frc::Pose2d, frc::ChassisSpeeds > | GetGoal () const |
| Gets the current goal. | |
| std::pair< frc::Pose2d, frc::ChassisSpeeds > | GetSetpoint () const |
| frc::ChassisSpeeds | Calculate (frc::Pose2d pose, frc::ChassisSpeeds currentSpeeds) |
| Calculates the required chassis speeds to reach the last set goal. This is an overload that uses the currently stored goal state. | |
| constexpr bool | AtGoal () const |
| constexpr bool | AtSetpoint () const |
| ProfiledPIDController< units::meter, units::meters_per_second > & | GetXController () |
| ProfiledPIDController< units::meter, units::meters_per_second > & | GetYController () |
| ProfiledPIDController< units::radian, units::radians_per_second > & | GetRotationalController () |
| void | LoggablePeriodic () override |
| Periodic callback for logging updates. | |
| Public Member Functions inherited from valor::Loggable | |
| Loggable (std::string_view name) | |
| Construct a Loggable that registers a top-level table name. | |
| Loggable (std::shared_ptr< nt::NetworkTable > table) | |
| Construct a Loggable that uses an existing NetworkTable. | |
| Loggable ()=default | |
| Default construct an uninitialized Loggable. | |
| void | LogChild (std::string_view name, Loggable *child) |
| Register a child Loggable under a named subtree. | |
| void | LogChild (std::string_view name, wpi::Sendable *child) |
| Register a child Sendable under a named subtree. | |
| bool | WriteLog (std::string_view field, bool data) |
| double | WriteLog (std::string_view field, double data) |
| void | WriteLog (std::string_view field, const std::vector< double > &data) |
|
template<typename U> requires units::traits::is_unit_t_v<U> | |
| U | WriteLog (std::string_view field, U data) |
| void | WriteLog (std::string_view field, std::string_view data) |
|
template<typename E> requires std::is_enum_v<E> | |
| void | WriteLog (std::string_view field, E data) |
|
template<typename T> requires wpi::StructSerializable<T> && (!std::is_arithmetic_v<T>) | |
| void | WriteLog (std::string_view field, const T &data) |
|
template<typename T> requires wpi::StructSerializable<T> && (!std::is_arithmetic_v<T>) | |
| void | WriteLog (std::string_view field, const std::vector< T > &data) |
| bool | ReadLog (std::string_view field, bool defaultValue) |
| double | ReadLog (std::string_view field, double defaultValue) |
|
template<typename U> requires units::traits::is_unit_t_v<U> | |
| U | ReadLog (std::string_view field, U defaultValue) |
Additional Inherited Members | |
| Public Types inherited from valor::WorldAlign | |
| using | TranslationalPIDF_t = valor::PIDF<units::meter, units::meters_per_second> |
| using | RotationalPIDF_t = valor::PIDF<units::radian, units::radians_per_second> |
| Static Public Member Functions inherited from valor::Loggable | |
| static constexpr Loggable & | GetRoot () |
| Protected Member Functions inherited from valor::Loggable | |
| virtual void | OnLoggingStart () |
| Hook invoked when logging is started for this object. | |
 1.15.0